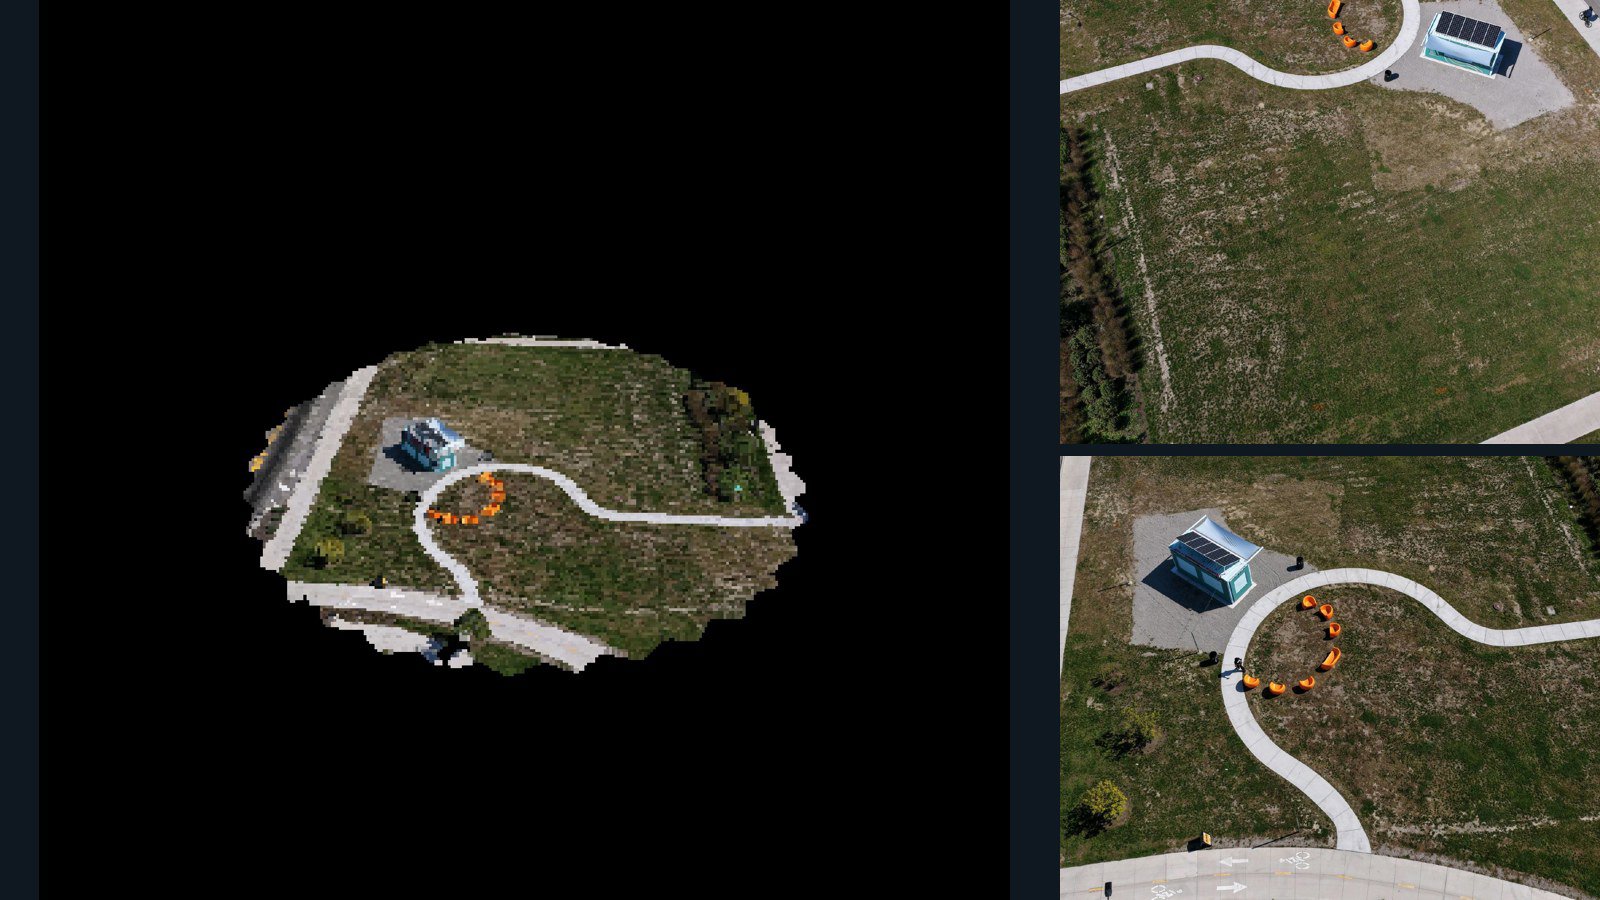
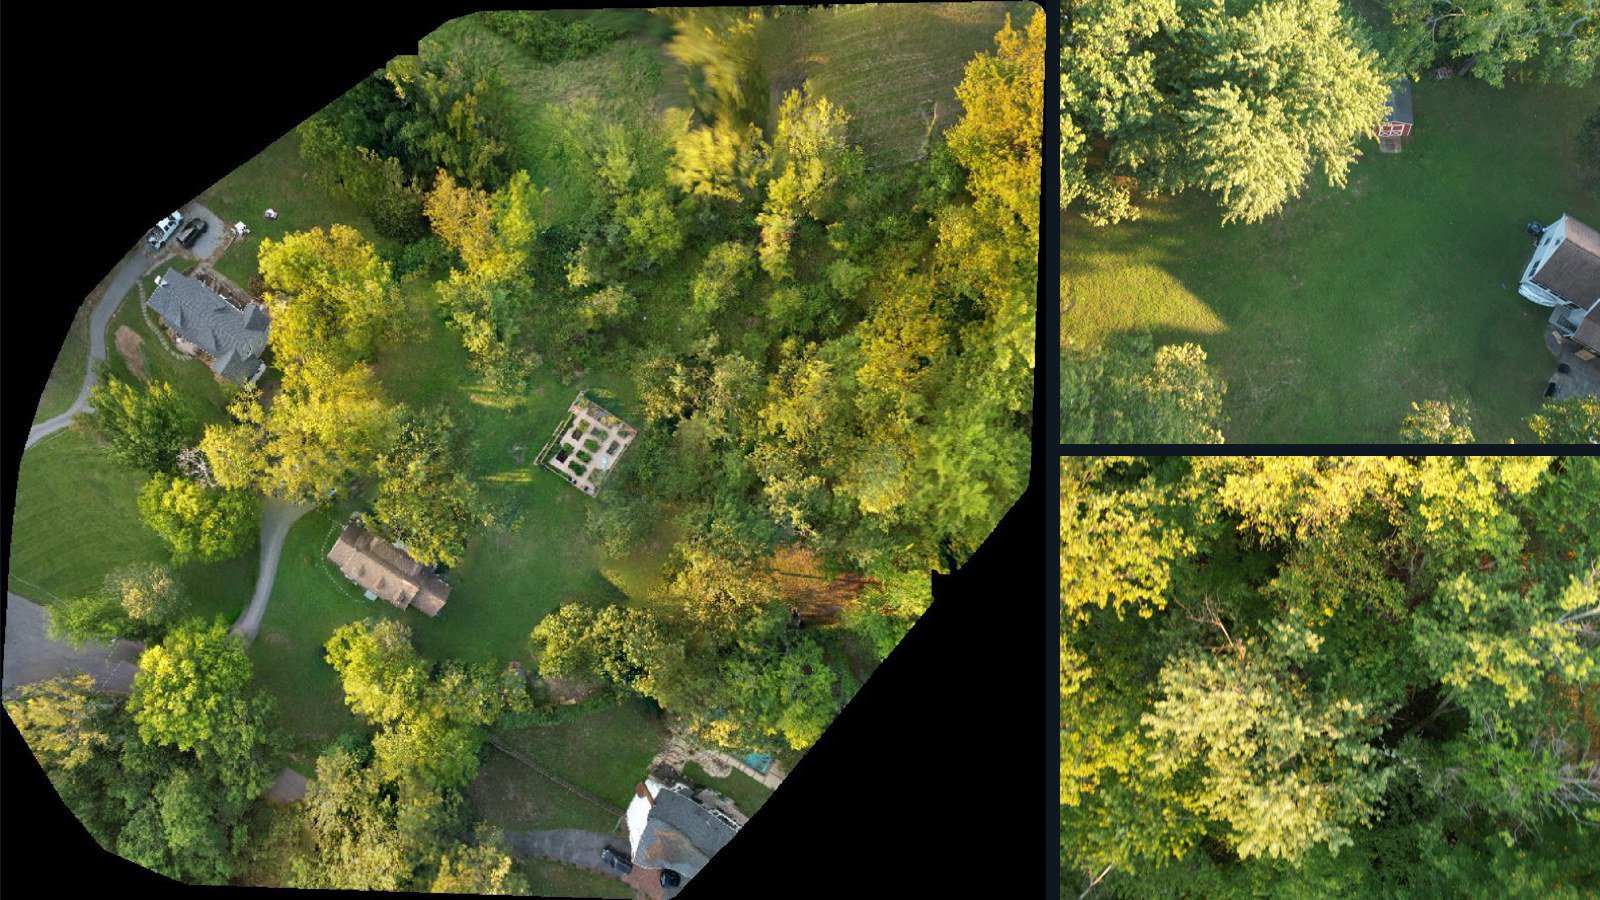
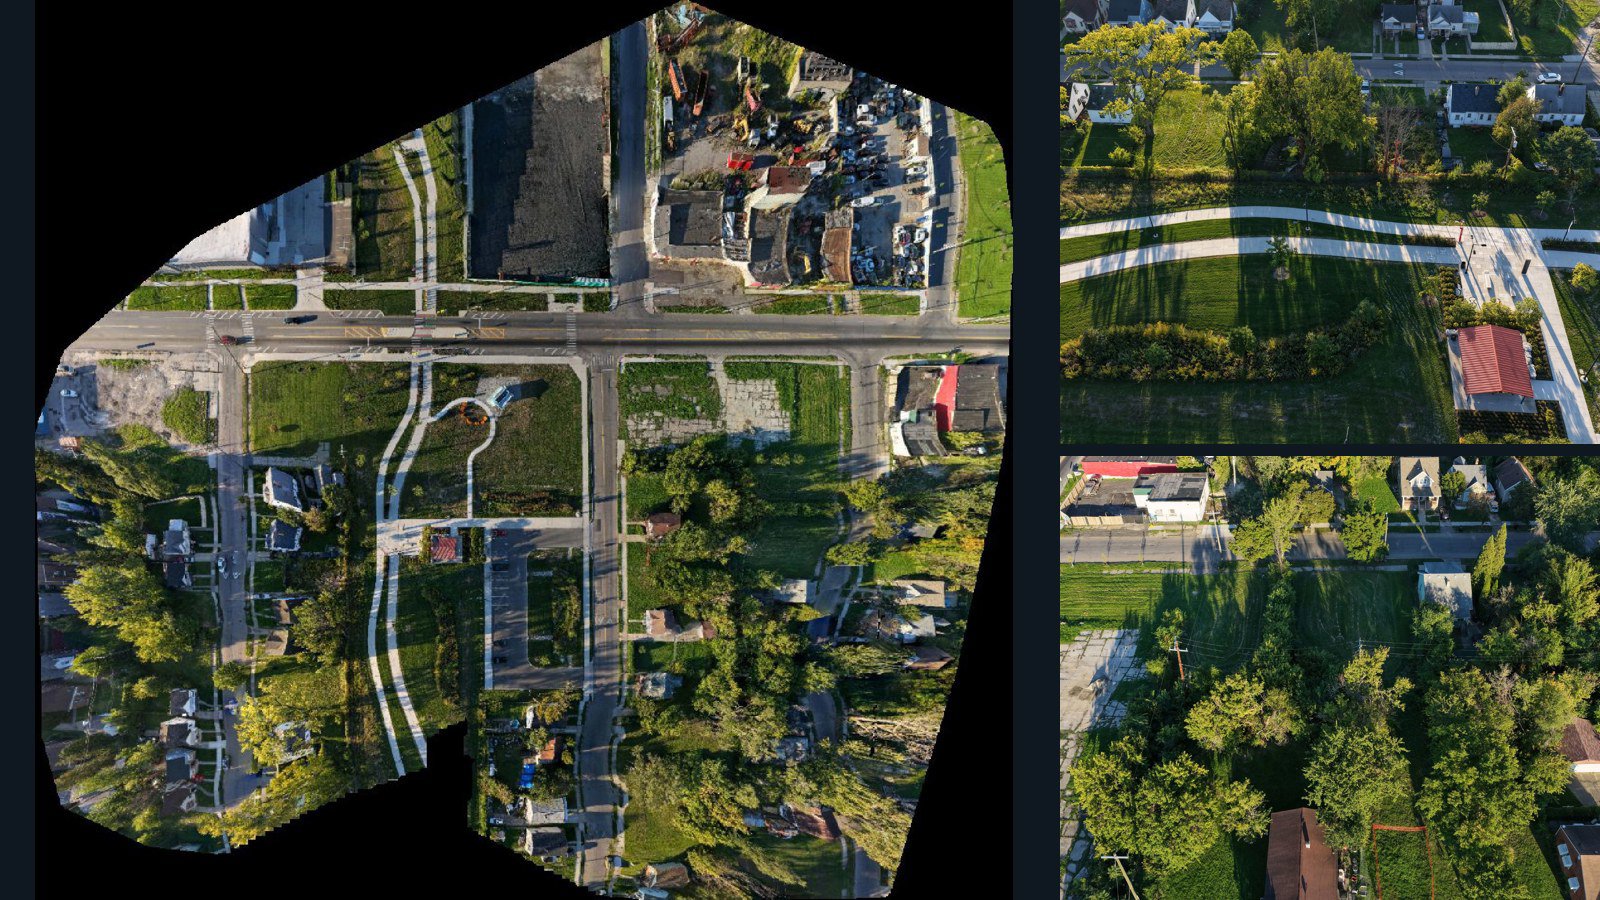
153source photos
6data types
4.2 GBfile inventory
1.16 cmreported GSD
EVALUATE THE REPRESENTATIONS TOGETHER
What connects in this scene?
Source imagery
Image files listedInspect overlap, resolution, coverage and image identifiers.
Camera data
Camera-data files listedVerify intrinsics, reconstructed poses and image mapping. File presence alone is not calibration.
3D geometry
Point cloud or mesh listedCheck coordinate units and reconstruction quality. Derived geometry is not independent ground truth.
These labels describe the retained inventory, not certified model readiness. Camera-data evaluation guide →
About this environment and capture
This scene from Detroit, Michigan, United States contains 153 retained original drone photographs captured with a L3D-100c camera, together with metadata, project bundles, camera data, point clouds, orthomosaics. Use the file inventory to compare the imagery and reconstruction products, and evaluate the available sample before requesting a license. The imagery provides overlapping observations of one scene; retained file counts do not imply unique ground coverage. Photogrammetric geometry and reported positioning estimates are not independent survey measurements. Commercial training, redistribution and production use require an appropriate written license.
Dataset compilation and curation: AerialDataset.
Retained scene representations
Counts and sizes reflect the files retained for this version.
Bundles may overlap with individual files. Storage totals are not unique ground coverage. Camera-data files may contain observations, calibration or reconstructed poses; inspect the sample and inventory for the exact contents.
Capture & geospatial details
- Location
- Detroit, Michigan, United States
- Capture date
- September 30, 2026Source capture metadata
- Camera
- L3D-100c
- Coordinate system
- EPSG:32617
- Reported ground sampling distance
- 1.16 cmOrthomosaic pixel size; not independent source-camera GSD
- Reported scene area
- 3.4 hectaresOrthomosaic raster extent; includes no-data pixels, not a surveyed boundary
- Public location precision
- Approximate scene location
- Scene coordinates
- 42.36, -83.15
Processing & output quality
Ortho-focused. Ortho optimization: the orthomosaic defaults to usable; the point cloud is not recommended.
- Orthomosaic
- Usable
- Point cloud
- Not recommended
Review statuses describe visual usability, not measured accuracy, RTK positioning or survey certification. Unlisted outputs are not included.
Accuracy & appropriate use
AerialAlign enhanced. The geospatial reconstruction has been aligned using AerialAlign. This is not a claim of RTK positioning or independent survey validation.
Source-reported post-alignment horizontal error estimate: 0.5 m. This is not an independent checkpoint measurement.
Geometry is reconstructed from imagery and is not independently surveyed ground truth. Source-reported horizontal error estimate: 0.5 m; not an independent checkpoint measurement.
Evaluate the supplied data against your own accuracy, rights and performance requirements before use.